Deep Learning
7 projects use this

Human Activity Classification Using Azure AutoML
Developed a data science pipeline using Azure ML, SQL, and machine learning models to classify human activity from sensor data, leveraging AutoML to achieve 94.1% accuracy with ensemble learning.

Multi-Class Animal Classification with CNNs
Trained and refined a multi-class CNN classifier using validation tracking, Adam optimization, learning rate scheduling, and regularization techniques to improve animal image recognition performance.

Reinforcement Learning: Neural Policy Optimization in CartPole
Implemented reinforcement learning with a neural network policy using the REINFORCE algorithm to solve OpenAI Gym’s CartPole-v1 task through Monte Carlo returns and gradient-based optimization.

Real-Time Trail Segmentation Model for An Autonomous Robot
Implemented deep learning-based semantic segmentation in PyTorch to classify outdoor trails, benchmarking multiple CNN architectures and optimizing LEDNet for accurate real-time robotic perception.
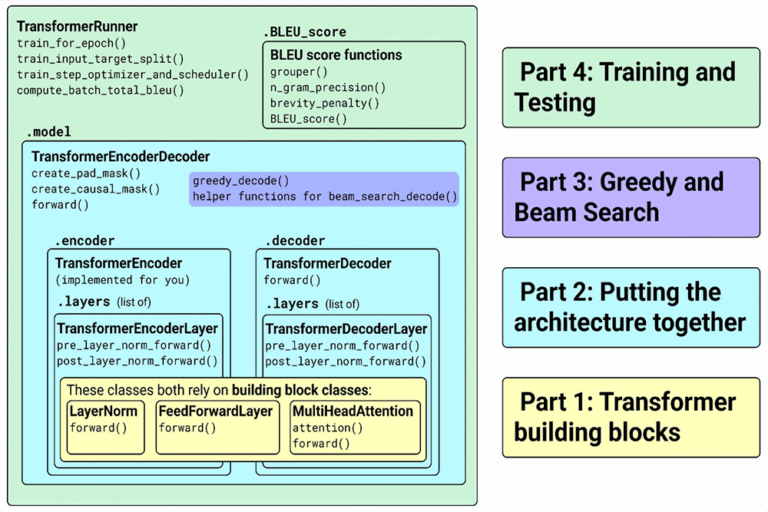
Transformer-Based English-to-French Translation
Built a custom Transformer architecture for machine translation using deep learning and NLP techniques, implementing attention mechanisms, positional encoding, and decoding strategies for language generation.
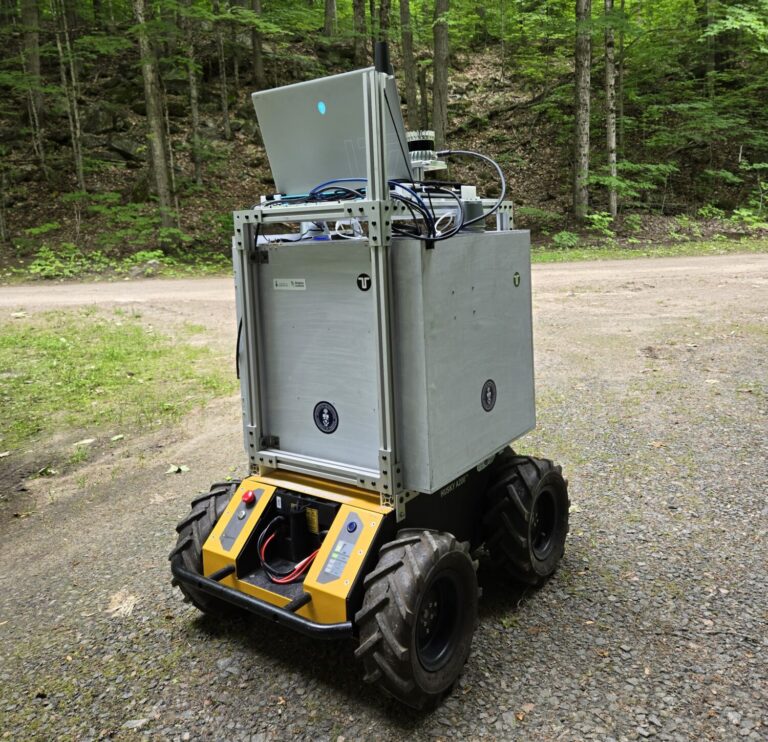
Robust Visual Navigation Using Semantic Segmentation and Sensor Fusion
Developed a ROS2 autonomous navigation pipeline using Python, OpenCV, PyTorch, and LEDNet for real-time trail segmentation, combining YOLOv7, lidar, and camera fusion for pedestrian-aware robotic navigation.

YOLO-Driven 3D Traffic Mapping from Stereo Camera
Engineered a 3D vision pipeline using Python, OpenCV, and YOLOv3 on KITTI stereo images, fusing depth maps with 2D detections to segment vehicles and estimate positions and distances.