Drones
4 projects use this

EKF-Based Probabilistic Localization Using Sensor Fusion
Implemented an Extended Kalman Filter for 2D robot localization, fusing wheel odometry and laser range data to estimate pose under noisy, partially observable environments with uncertain measurements.

Georeferenced Ground Targets Using UAV Imagery
Built a Python pipeline using OpenCV, HSV segmentation, and K Means clustering to detect targets from drone imagery and transform them into global coordinates via calibrated camera models.
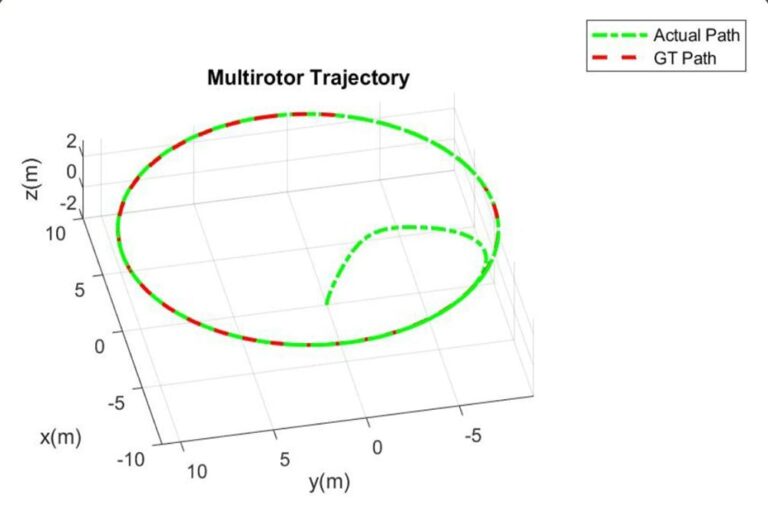
Dynamic Modeling and Control of a UAV in Simulink
Designed a MATLAB/Simulink quadrotor control system using state-space modeling, kinematics, and cascaded PID control to simulate UAV flight dynamics, stability, and path tracking performance.
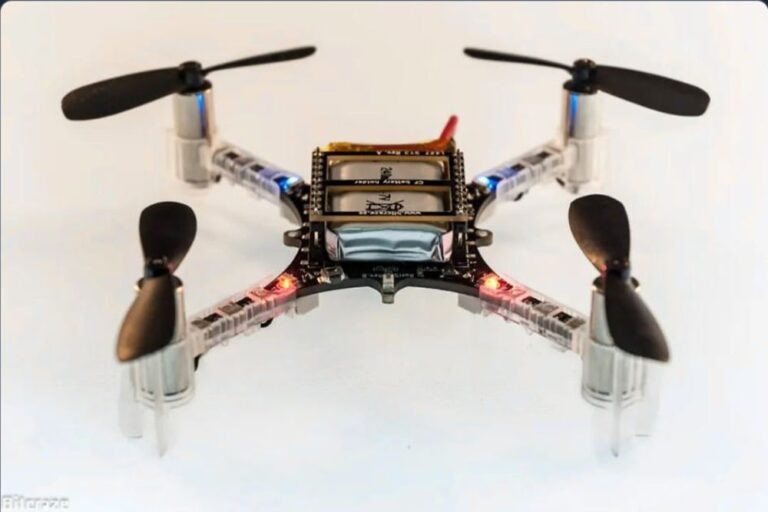
Sim to Real Drone Racing with RRT* Planning
Developed autonomous drone racing capabilities using Python, RRT*, and PyBullet, combining trajectory optimization, polynomial path fitting, and sim-to-real deployment on a Crazyflie quadrotor.