MATLAB
6 projects use this

Oscilloscope Analog Interface and PCB Design
Designed a custom 2-layer analog PCB in Eagle for an oscilloscope system, implementing signal conditioning, op-amp amplification, filtering, protection circuits, and power conversion.

Embedded Omni Directional Maze Navigating Robot with 360 LiDAR
Designed an autonomous maze-navigation robot using Raspberry Pi and Arduino microcontrollers, integrating LiDAR, sensor fusion, and real-time communication via USB, I2C, and SPI protocols.
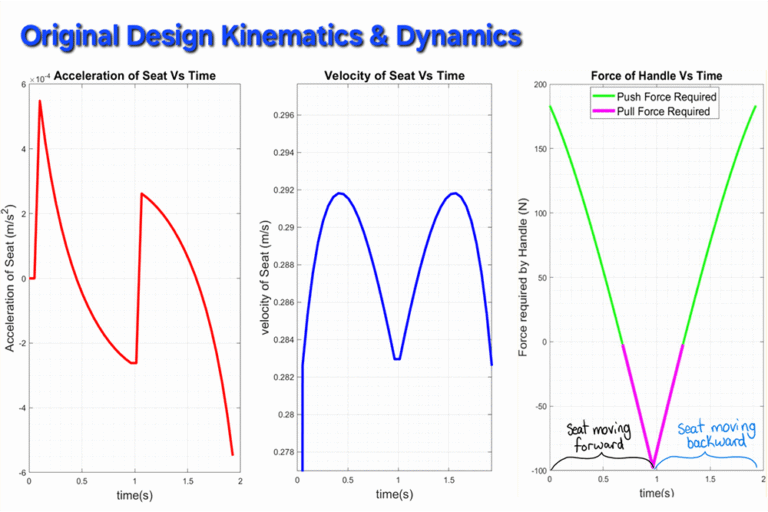
Dynamic Force Analysis and Redesign of an Outdoor Rowing Machine
Redesigned an outdoor rowing machine using MATLAB-based dynamics analysis and a parallelogram linkage mechanism to stabilize force output, optimize motion, and improve user performance.

Maze Navigating Robot Localization Using 2D LiDAR and Particle Filter SLAM
Led software development for a ROS-based autonomous robot using Python, C++, LiDAR, Hector SLAM, and AMCL for mapping, localization, and navigation with real-time obstacle avoidance.
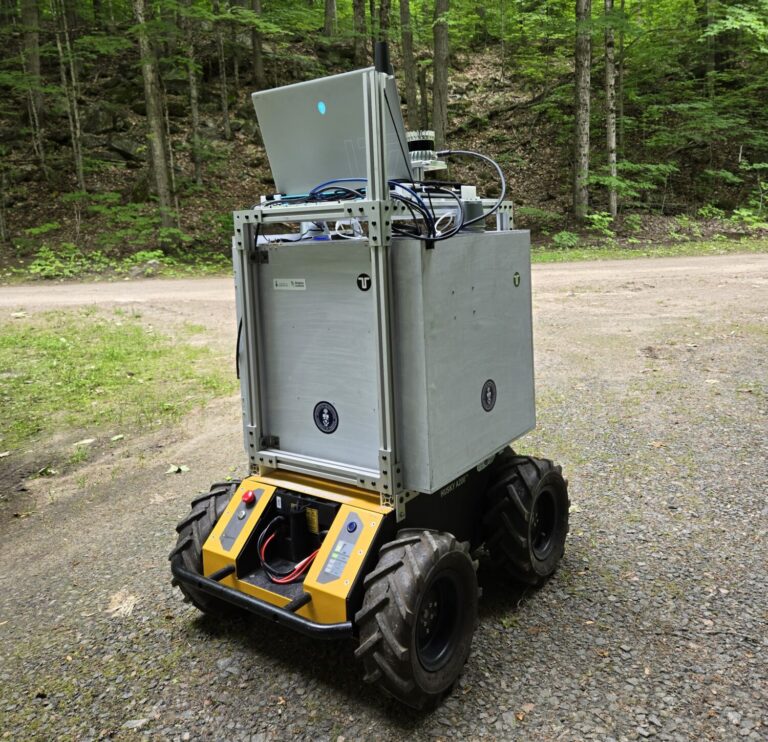
Robust Visual Navigation Using Semantic Segmentation and Sensor Fusion
Developed a ROS2 autonomous navigation pipeline using Python, OpenCV, PyTorch, and LEDNet for real-time trail segmentation, combining YOLOv7, lidar, and camera fusion for pedestrian-aware robotic navigation.
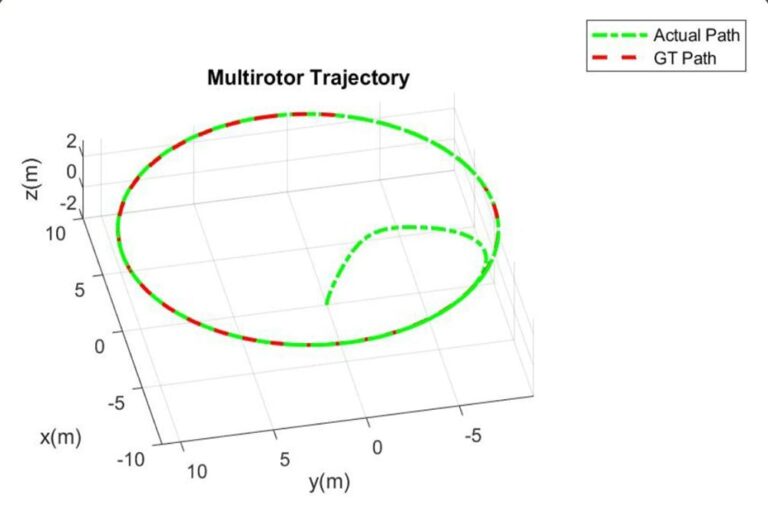
Dynamic Modeling and Control of a UAV in Simulink
Designed a MATLAB/Simulink quadrotor control system using state-space modeling, kinematics, and cascaded PID control to simulate UAV flight dynamics, stability, and path tracking performance.