OpenCV
5 projects use this

Gesture-Controlled Robot with Raspberry Pi and Arduino Integration
Created an embedded human-robot interaction system where a sensor-equipped glove controlled a robotic vehicle via gestures, combining Arduino, Raspberry Pi, ROS, and wireless communication.

Drift Resilient Visual Odometry with Stereo Vision
Developed a Python visual odometry system using OpenCV and NumPy to estimate vehicle pose and localization from KITTI stereo images, leveraging RANSAC, point cloud alignment, and SVD.
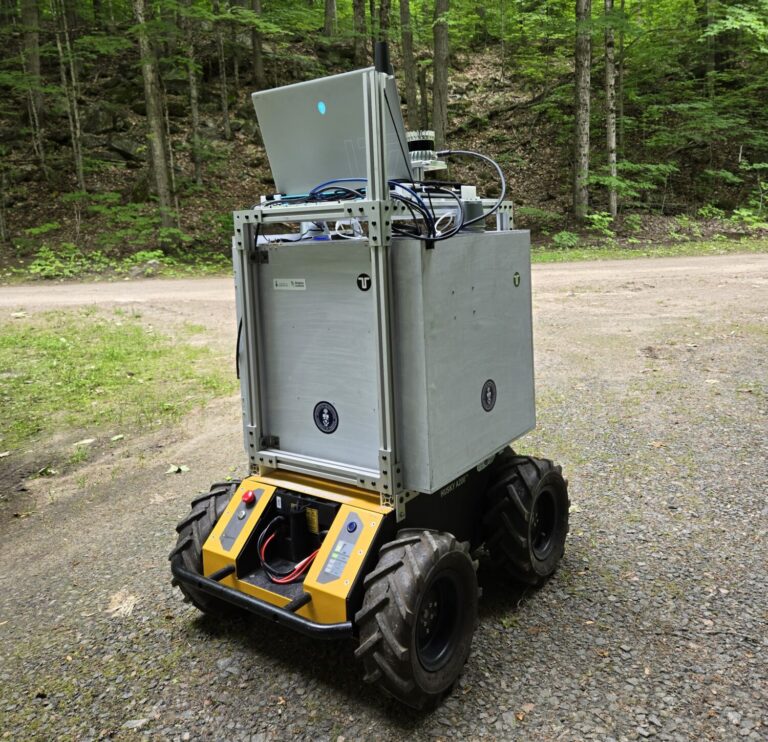
Robust Visual Navigation Using Semantic Segmentation and Sensor Fusion
Developed a ROS2 autonomous navigation pipeline using Python, OpenCV, PyTorch, and LEDNet for real-time trail segmentation, combining YOLOv7, lidar, and camera fusion for pedestrian-aware robotic navigation.

YOLO-Driven 3D Traffic Mapping from Stereo Camera
Engineered a 3D vision pipeline using Python, OpenCV, and YOLOv3 on KITTI stereo images, fusing depth maps with 2D detections to segment vehicles and estimate positions and distances.

Georeferenced Ground Targets Using UAV Imagery
Built a Python pipeline using OpenCV, HSV segmentation, and K Means clustering to detect targets from drone imagery and transform them into global coordinates via calibrated camera models.