Optimization
9 projects use this

Multi-Class Animal Classification with CNNs
Trained and refined a multi-class CNN classifier using validation tracking, Adam optimization, learning rate scheduling, and regularization techniques to improve animal image recognition performance.

Geolocating Fuel Stations Using Vehicle Telematics and BigQuery
Built a scalable geospatial analytics pipeline using SQL, BigQuery, and DBSCAN to identify public gas stations from millions of vehicle fuel events while filtering false positives.

Manipulator Trajectory Optimization Using Interior Point Methods
Implemented optimal trajectory planning for a 2-DOF robotic manipulator using CasADi and IPopt, applying direct optimal control to optimize motion for energy, time, and torque objectives.

Sampling-Based Motion Planning: Speed vs. Optimality
Compared sampling-based motion planners in Python by applying RRT and RRT* to a Dubins vehicle, demonstrating improved path optimality through rewiring while respecting vehicle constraints.

Drift Resilient Visual Odometry with Stereo Vision
Developed a Python visual odometry system using OpenCV and NumPy to estimate vehicle pose and localization from KITTI stereo images, leveraging RANSAC, point cloud alignment, and SVD.

EKF-Based Probabilistic Localization Using Sensor Fusion
Implemented an Extended Kalman Filter for 2D robot localization, fusing wheel odometry and laser range data to estimate pose under noisy, partially observable environments with uncertain measurements.

Georeferenced Ground Targets Using UAV Imagery
Built a Python pipeline using OpenCV, HSV segmentation, and K Means clustering to detect targets from drone imagery and transform them into global coordinates via calibrated camera models.

3D Point Cloud Matching Using SVD and ICP
Created a 3D point cloud alignment system in Python using the ICP algorithm, nearest-neighbour search, and SVD to estimate optimal transformations between source and target scans.
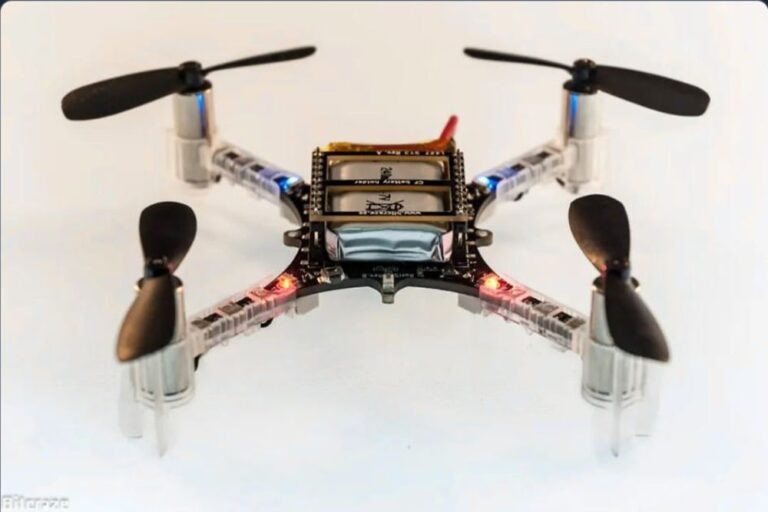
Sim to Real Drone Racing with RRT* Planning
Developed autonomous drone racing capabilities using Python, RRT*, and PyBullet, combining trajectory optimization, polynomial path fitting, and sim-to-real deployment on a Crazyflie quadrotor.