Python
19 projects use this

Human Activity Classification Using Azure AutoML
Developed a data science pipeline using Azure ML, SQL, and machine learning models to classify human activity from sensor data, leveraging AutoML to achieve 94.1% accuracy with ensemble learning.
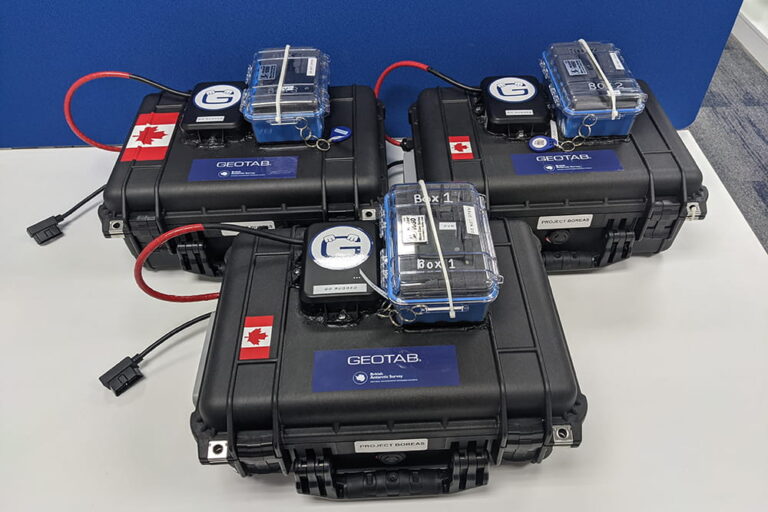
Automated Cloud Pipeline for Antarctic Environmental Sensor Data
Automated a Google Cloud data pipeline using Python, SQL, Apps Script, Cloud Functions, and BigQuery to ingest, clean, store, and analyze environmental sensor data from Antarctica.

Multi-Class Animal Classification with CNNs
Trained and refined a multi-class CNN classifier using validation tracking, Adam optimization, learning rate scheduling, and regularization techniques to improve animal image recognition performance.

Reinforcement Learning: Neural Policy Optimization in CartPole
Implemented reinforcement learning with a neural network policy using the REINFORCE algorithm to solve OpenAI Gym’s CartPole-v1 task through Monte Carlo returns and gradient-based optimization.

Real-Time Trail Segmentation Model for An Autonomous Robot
Implemented deep learning-based semantic segmentation in PyTorch to classify outdoor trails, benchmarking multiple CNN architectures and optimizing LEDNet for accurate real-time robotic perception.

Real-Time Monitoring of eMMC Health in IoT Devices
Investigated hardware reliability in embedded telematics devices through eMMC wear analysis, using diagnostic data to assess memory degradation, wear leveling, and potential failure modes.

Embedded Omni Directional Maze Navigating Robot with 360 LiDAR
Designed an autonomous maze-navigation robot using Raspberry Pi and Arduino microcontrollers, integrating LiDAR, sensor fusion, and real-time communication via USB, I2C, and SPI protocols.

Gesture-Controlled Robot with Raspberry Pi and Arduino Integration
Created an embedded human-robot interaction system where a sensor-equipped glove controlled a robotic vehicle via gestures, combining Arduino, Raspberry Pi, ROS, and wireless communication.
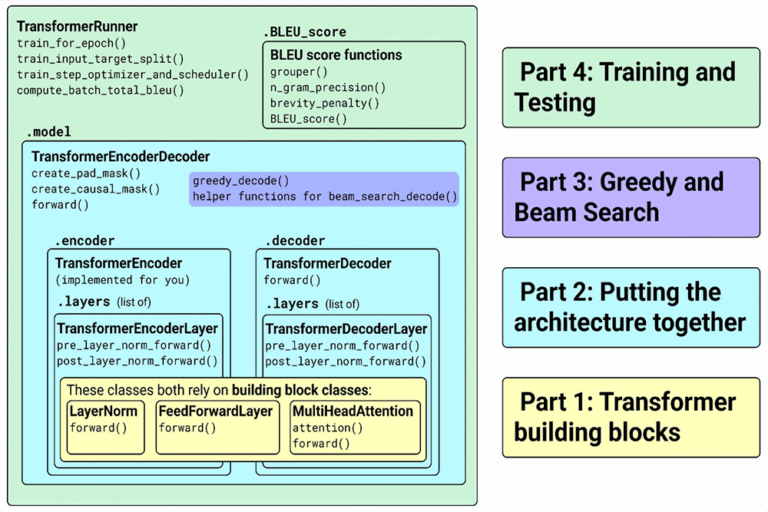
Transformer-Based English-to-French Translation
Built a custom Transformer architecture for machine translation using deep learning and NLP techniques, implementing attention mechanisms, positional encoding, and decoding strategies for language generation.
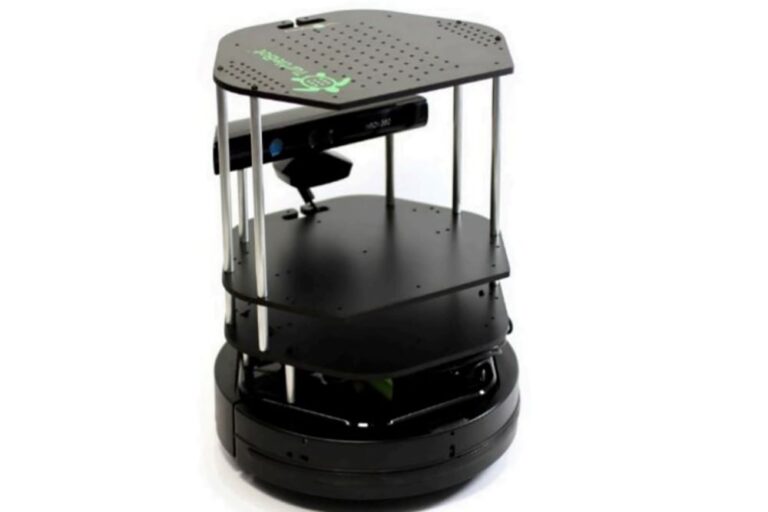
Adaptive Heuristic Exploration for Autonomous Mapping on Turtlebot
Developed autonomous navigation algorithms for Turtlebot using ROS, Python, C++, and Gazebo, combining heuristic planning and sensor feedback to optimize exploration paths in unknown environments.

Manipulator Trajectory Optimization Using Interior Point Methods
Implemented optimal trajectory planning for a 2-DOF robotic manipulator using CasADi and IPopt, applying direct optimal control to optimize motion for energy, time, and torque objectives.

Sampling-Based Motion Planning: Speed vs. Optimality
Compared sampling-based motion planners in Python by applying RRT and RRT* to a Dubins vehicle, demonstrating improved path optimality through rewiring while respecting vehicle constraints.

Drift Resilient Visual Odometry with Stereo Vision
Developed a Python visual odometry system using OpenCV and NumPy to estimate vehicle pose and localization from KITTI stereo images, leveraging RANSAC, point cloud alignment, and SVD.

Maze Navigating Robot Localization Using 2D LiDAR and Particle Filter SLAM
Led software development for a ROS-based autonomous robot using Python, C++, LiDAR, Hector SLAM, and AMCL for mapping, localization, and navigation with real-time obstacle avoidance.
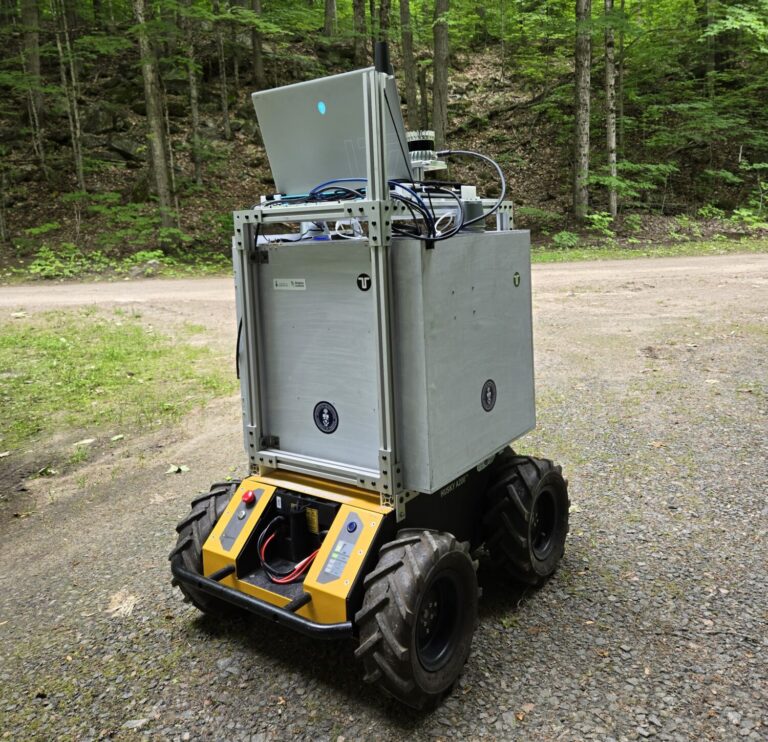
Robust Visual Navigation Using Semantic Segmentation and Sensor Fusion
Developed a ROS2 autonomous navigation pipeline using Python, OpenCV, PyTorch, and LEDNet for real-time trail segmentation, combining YOLOv7, lidar, and camera fusion for pedestrian-aware robotic navigation.

YOLO-Driven 3D Traffic Mapping from Stereo Camera
Engineered a 3D vision pipeline using Python, OpenCV, and YOLOv3 on KITTI stereo images, fusing depth maps with 2D detections to segment vehicles and estimate positions and distances.

Georeferenced Ground Targets Using UAV Imagery
Built a Python pipeline using OpenCV, HSV segmentation, and K Means clustering to detect targets from drone imagery and transform them into global coordinates via calibrated camera models.

3D Point Cloud Matching Using SVD and ICP
Created a 3D point cloud alignment system in Python using the ICP algorithm, nearest-neighbour search, and SVD to estimate optimal transformations between source and target scans.
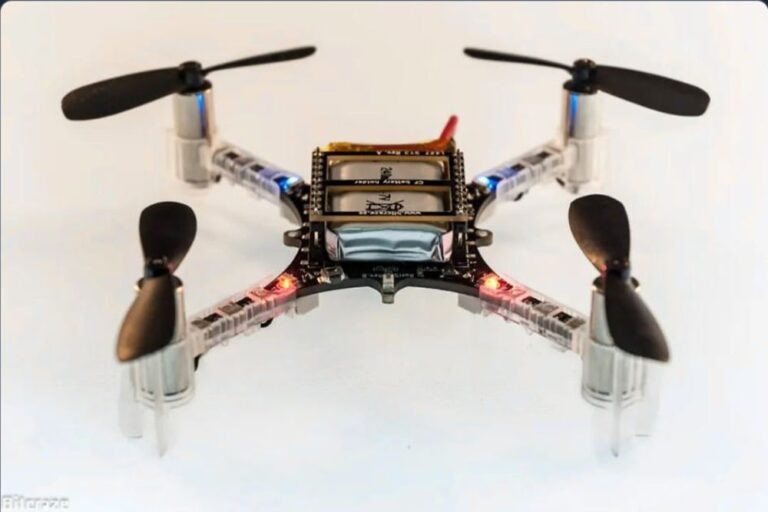
Sim to Real Drone Racing with RRT* Planning
Developed autonomous drone racing capabilities using Python, RRT*, and PyBullet, combining trajectory optimization, polynomial path fitting, and sim-to-real deployment on a Crazyflie quadrotor.