Robotics · Drones & Aerial Robotics
Dynamic Modeling and Control of a UAV in Simulink
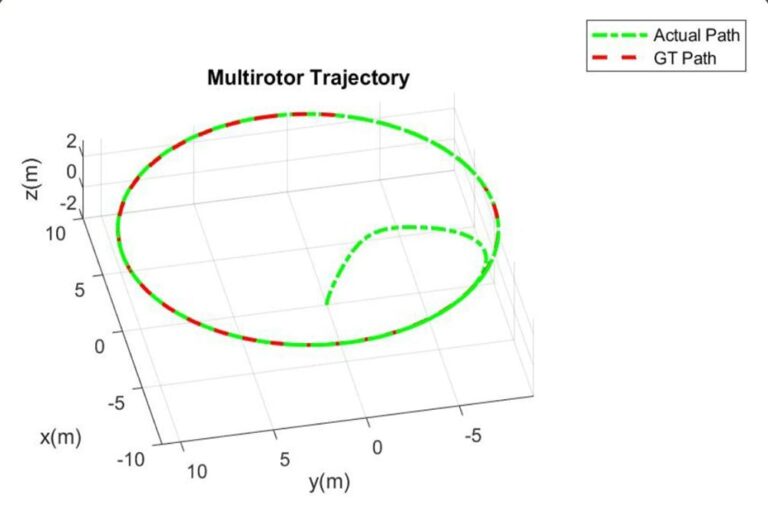
Designed a MATLAB/Simulink quadrotor control system using state-space modeling, kinematics, and cascaded PID control to simulate UAV flight dynamics, stability, and path tracking performance.