C++
7 projects use this

Microcontroller-Driven Beverage Automation Platform
Prototyped an embedded control system using Arduino Mega, integrating PWM actuators, UART/I2C communication, sensors, and user interfaces to automate a custom drink-mixing machine.
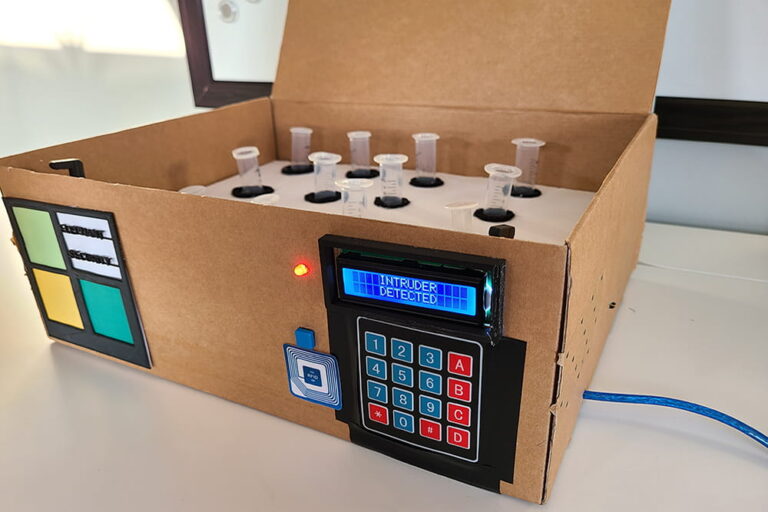
U of T Design League Winner Secure Embedded Vaccine Transport
Prototyped an Arduino-based embedded security system for temperature-controlled transport, integrating sensors, servo actuators, keypad access, and Fusion360 CAD design during a 24-hour design challenge.

Embedded Omni Directional Maze Navigating Robot with 360 LiDAR
Designed an autonomous maze-navigation robot using Raspberry Pi and Arduino microcontrollers, integrating LiDAR, sensor fusion, and real-time communication via USB, I2C, and SPI protocols.
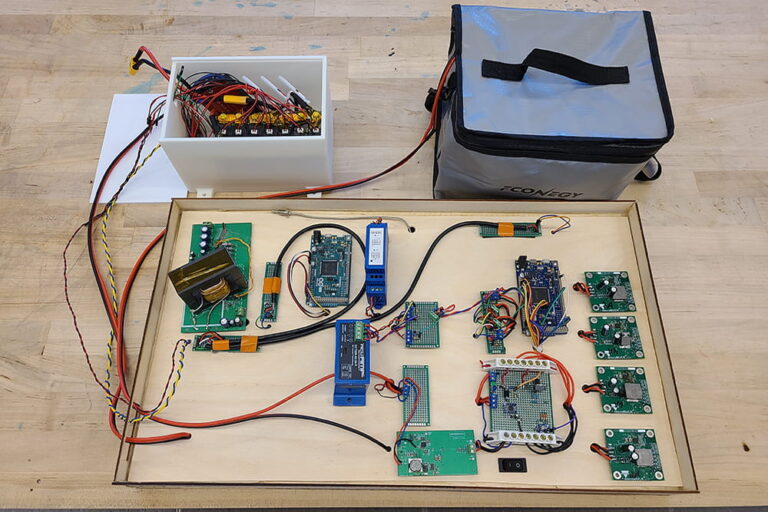
Battery Characterization and PCB Assembly for High-Voltage Electric Vehicle
Integrated a 288V lithium-ion battery system for a high-speed EV, performing cell testing, thermal validation, and electrical assembly of PCBs, converters, sensors, and power electronics.

Gesture-Controlled Robot with Raspberry Pi and Arduino Integration
Created an embedded human-robot interaction system where a sensor-equipped glove controlled a robotic vehicle via gestures, combining Arduino, Raspberry Pi, ROS, and wireless communication.
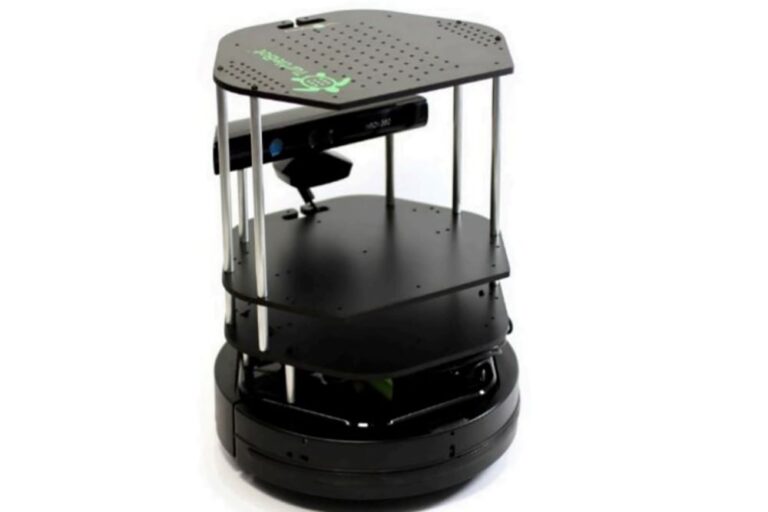
Adaptive Heuristic Exploration for Autonomous Mapping on Turtlebot
Developed autonomous navigation algorithms for Turtlebot using ROS, Python, C++, and Gazebo, combining heuristic planning and sensor feedback to optimize exploration paths in unknown environments.

Maze Navigating Robot Localization Using 2D LiDAR and Particle Filter SLAM
Led software development for a ROS-based autonomous robot using Python, C++, LiDAR, Hector SLAM, and AMCL for mapping, localization, and navigation with real-time obstacle avoidance.